Welcome to the Intelligent Systems and Learning (ISL) Lab at DGIST, led by Prof. Daehee Park.
Our mission is to bridge the gap between artificial intelligence and the physical world.
Moving beyond traditional model scaling paradigms, we strive to advance a new generation of practical and deployable Physical AI capable of operating reliably in complex, real-world environments.
We are always looking for passionate students who want to push the boundaries of AI. Join us →
Research Topics
Rollout
Evolving
Self-Evolving A.I.
Building AI systems that autonomously improve through interaction with the environment, enabling continual learning, test-time adaptation, and self-refinement without human intervention.
AgileX
Arx-X5
Robotics AI
Advancing the frontier of Embodied AI by integrating multimodal perception with real-world robotic control to automate complex physical tasks.
Knowledge Integration
Research on integrating knowledge from multiple sources and modalities to enhance AI systems' understanding and decision-making capabilities.
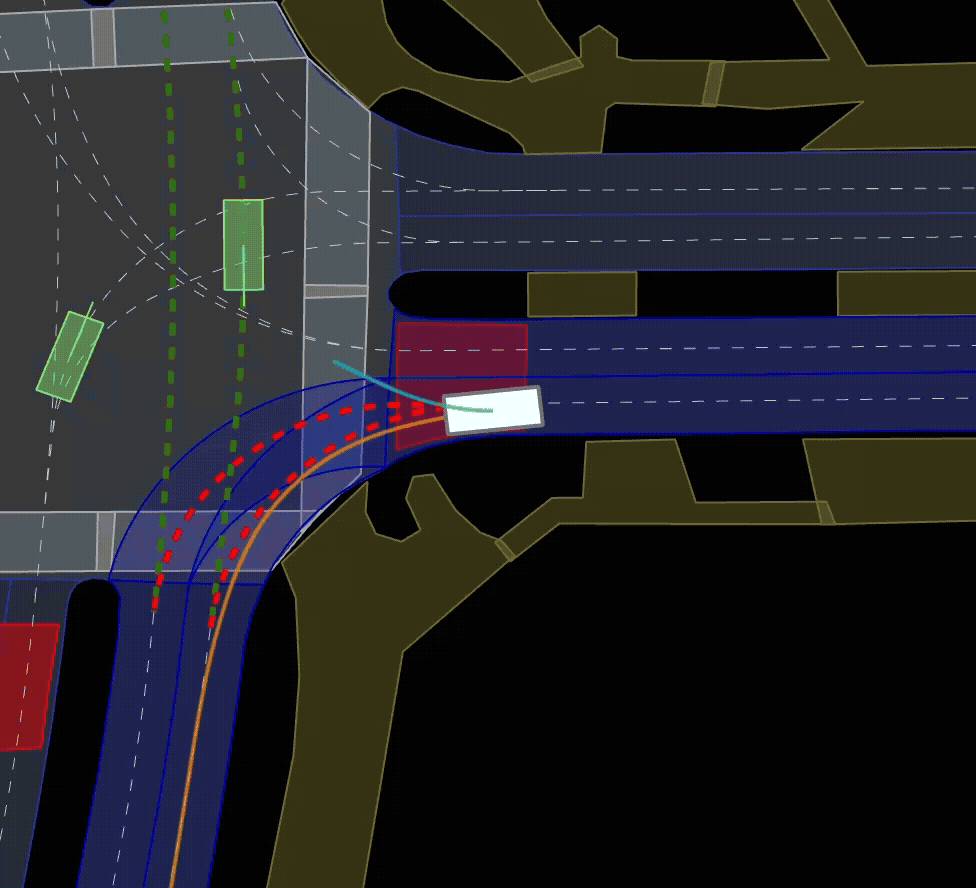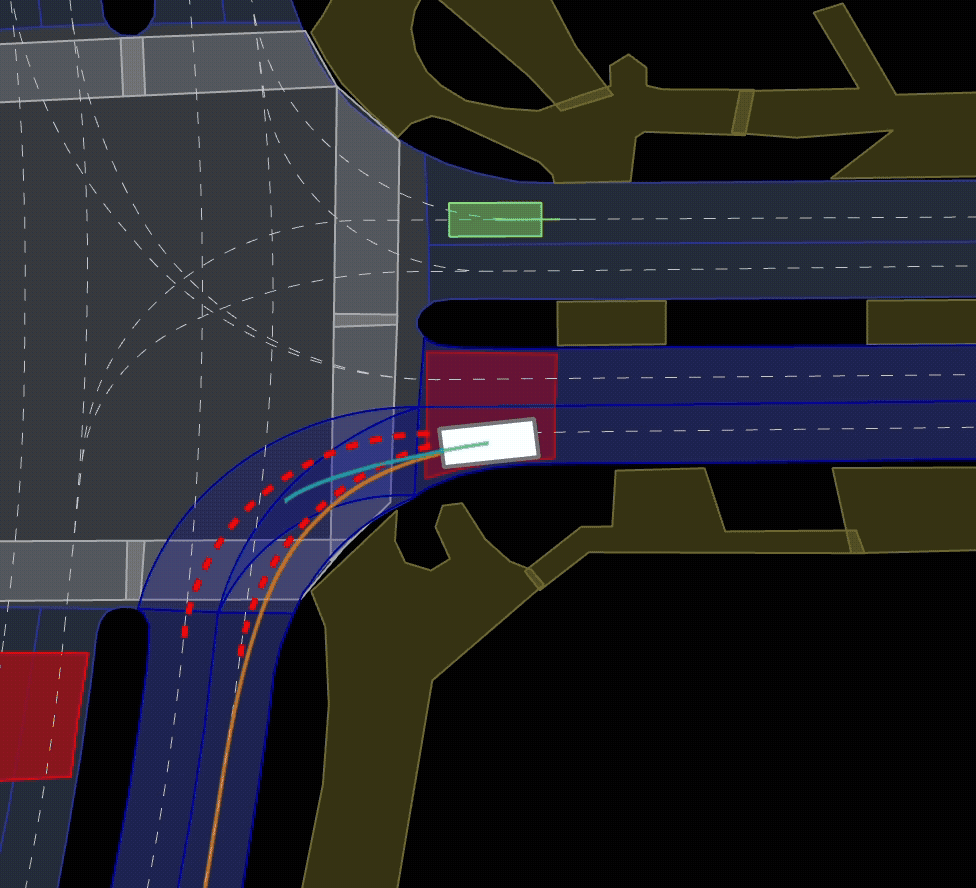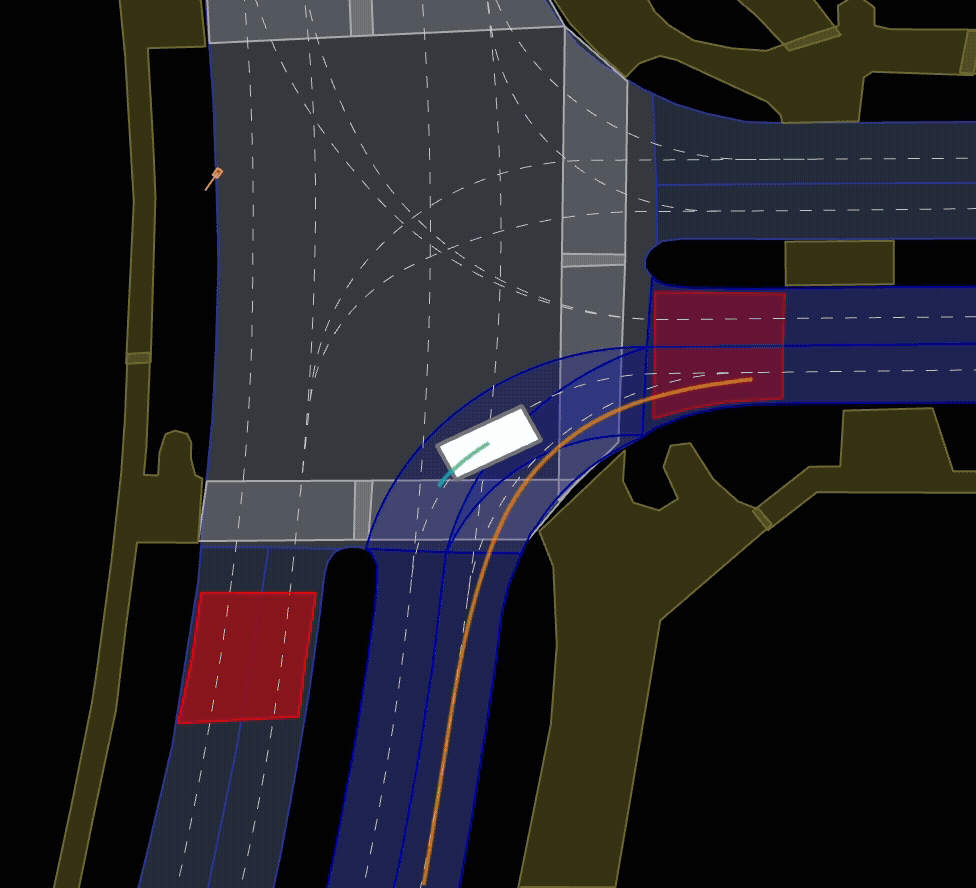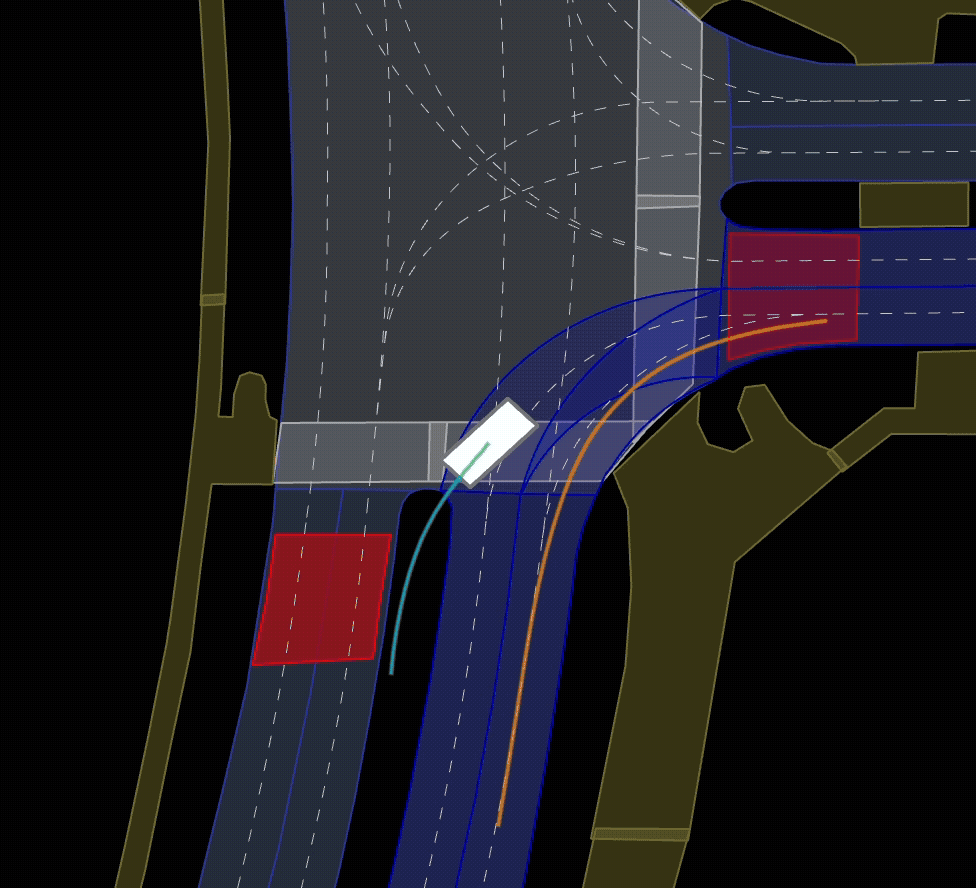
Chat Driving
Attack Driving
Autonomous Driving
Enabling safe and intelligent autonomous driving through trajectory prediction, motion planning, and multimodal scene understanding for real-world environments.
World Model Sample 1
World Model Sample 2
World Model
Developing internal models that allow AI systems to predict, simulate, and reason about future states of the world, enabling more robust planning and decision-making under uncertainty.
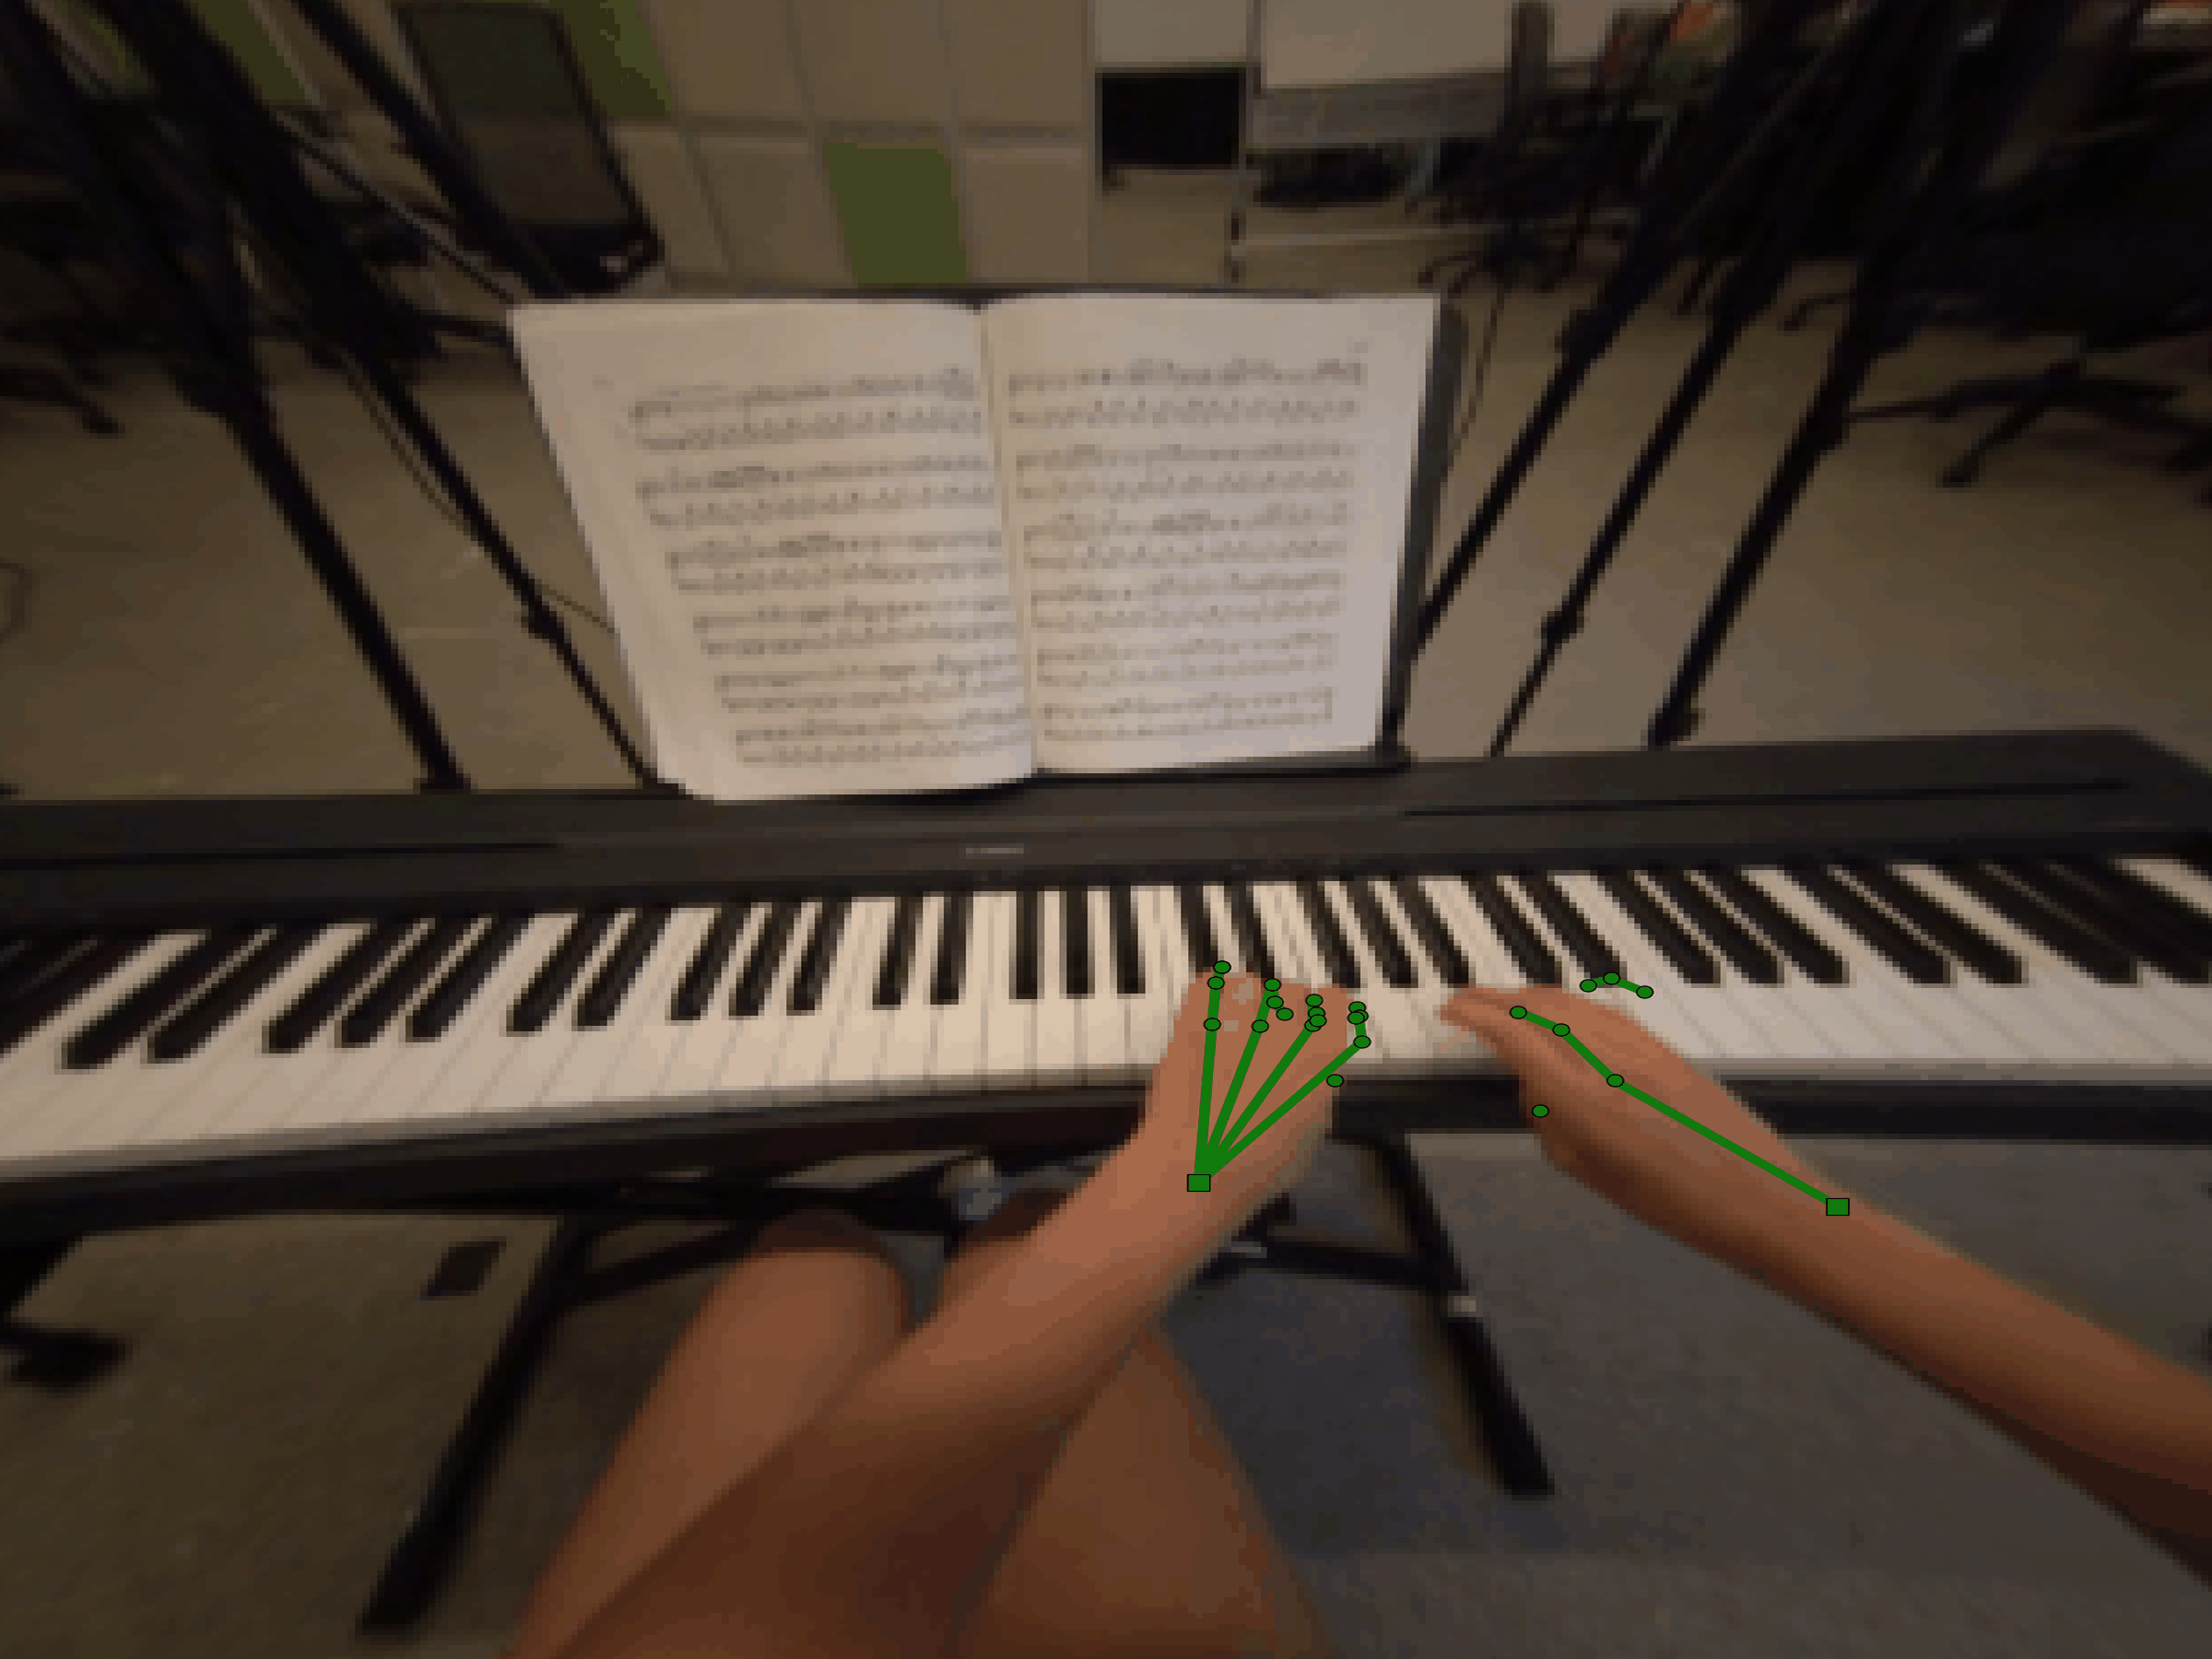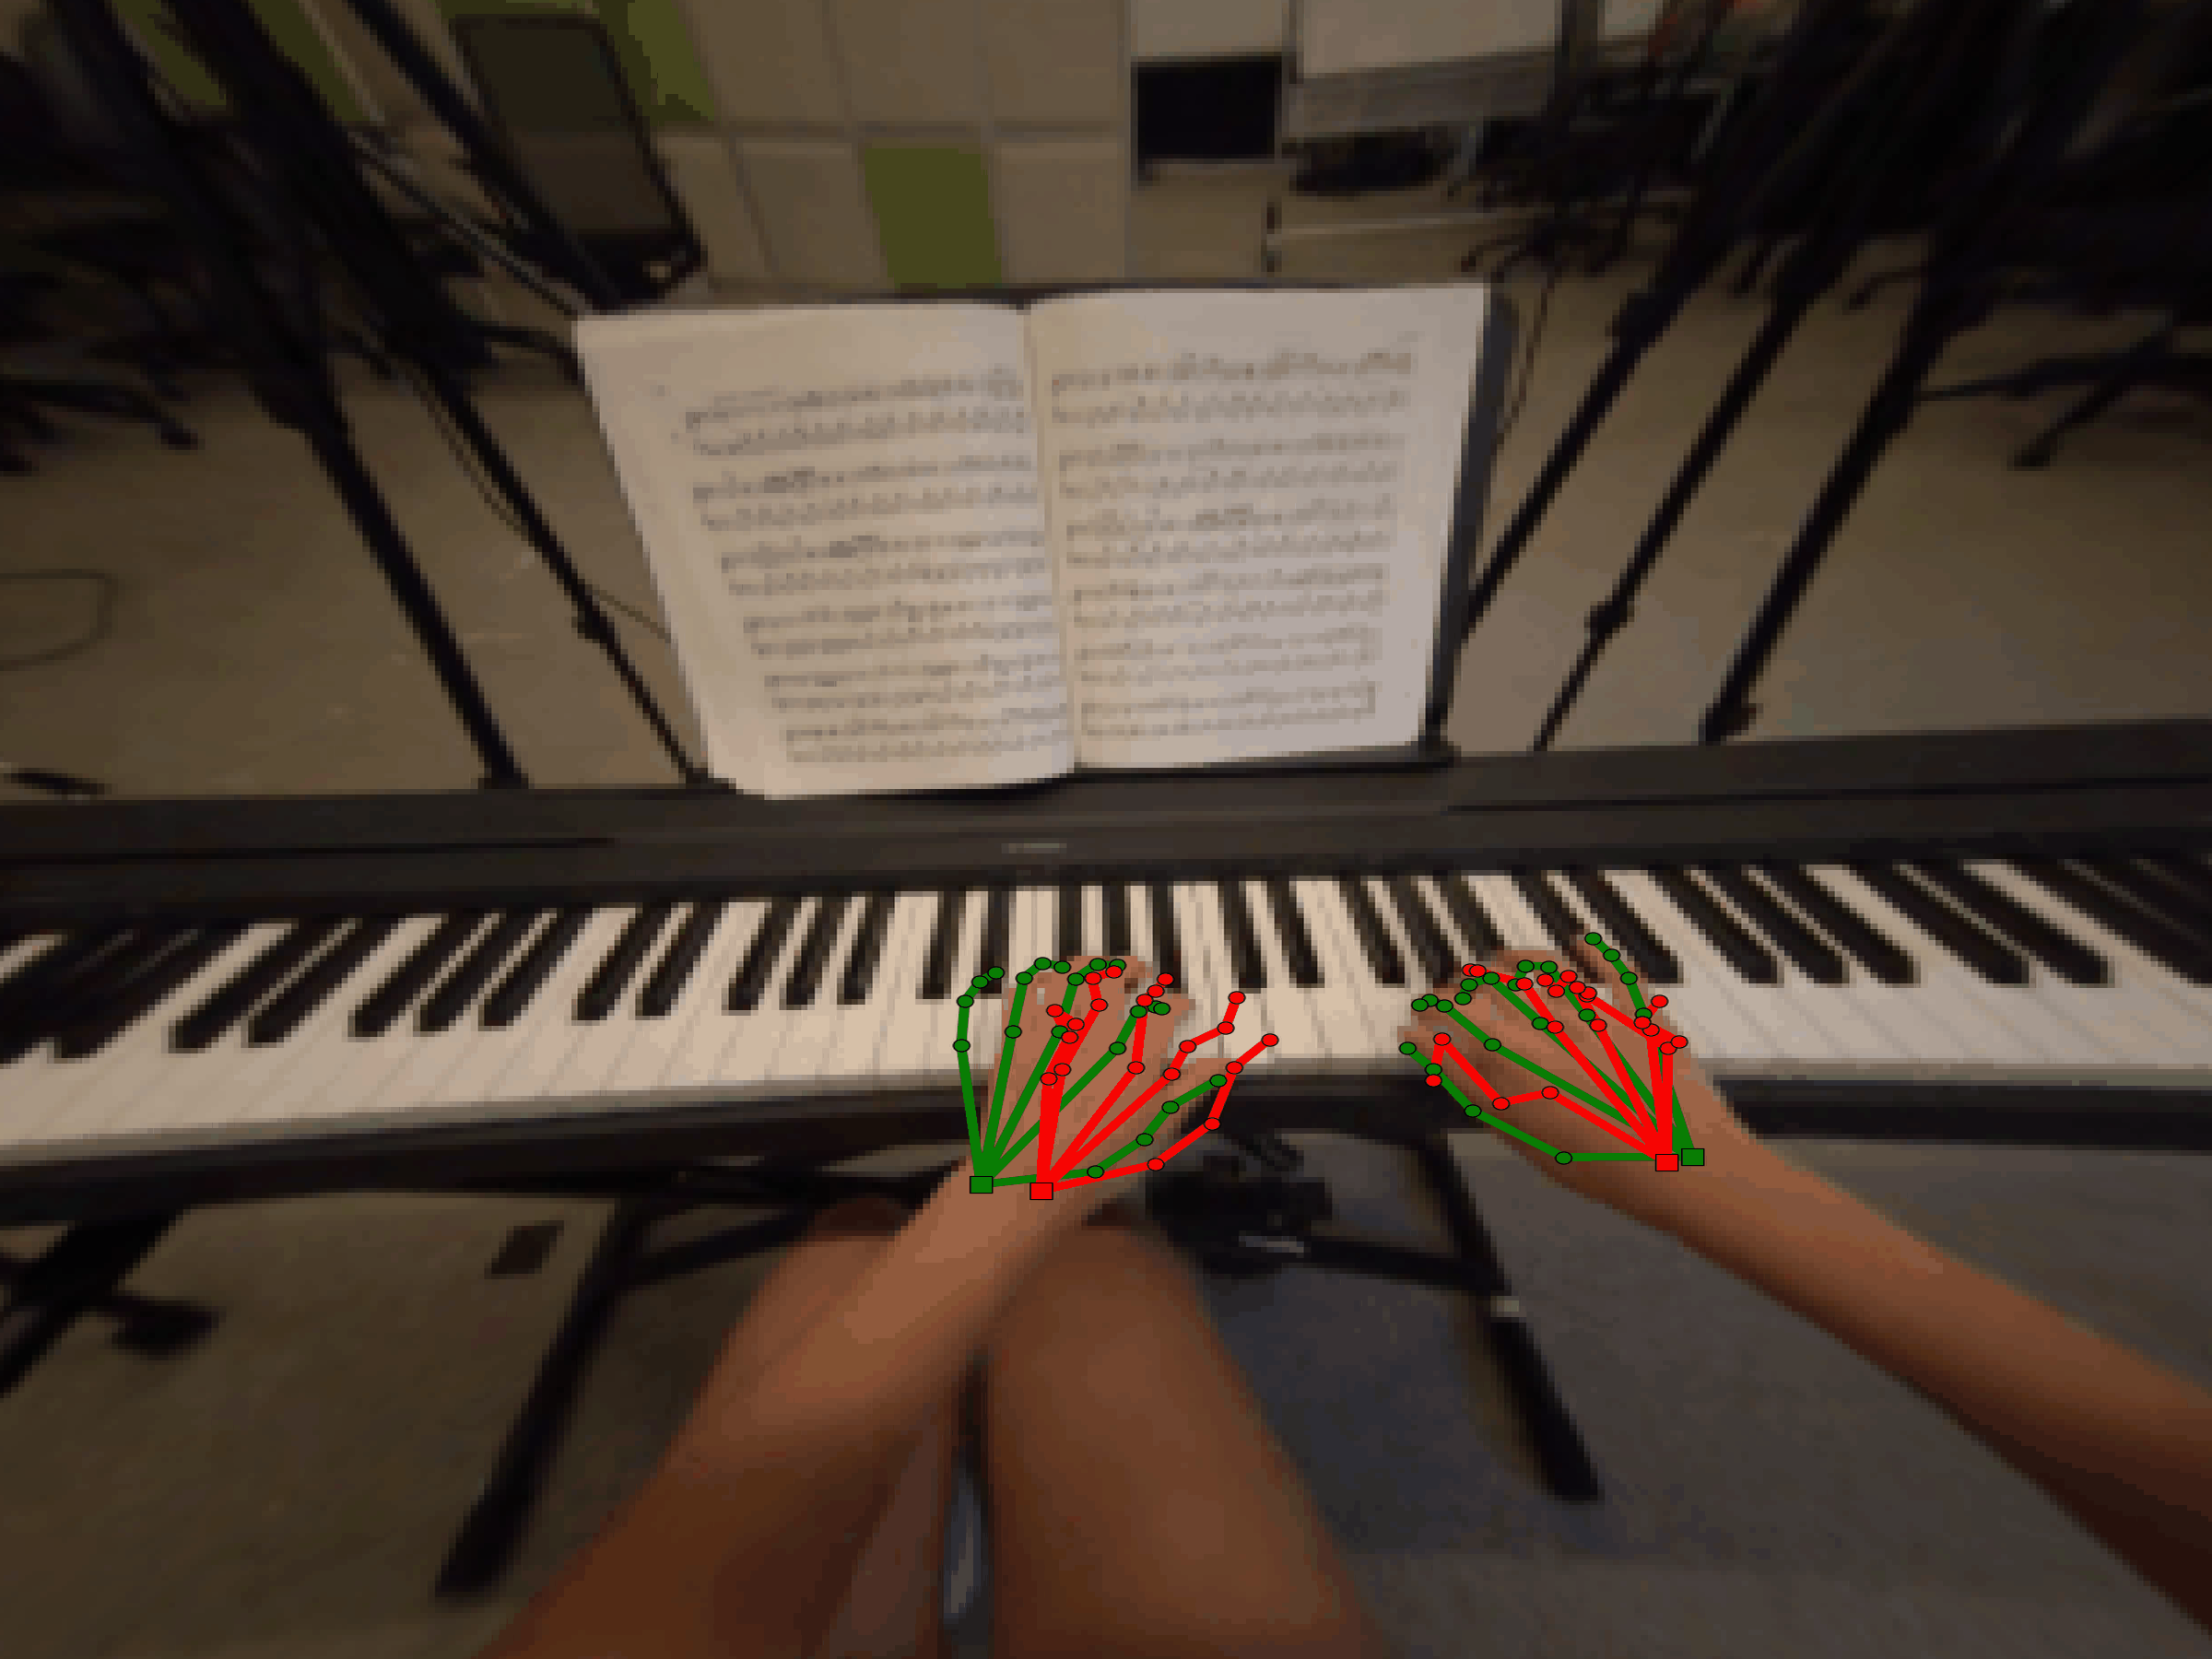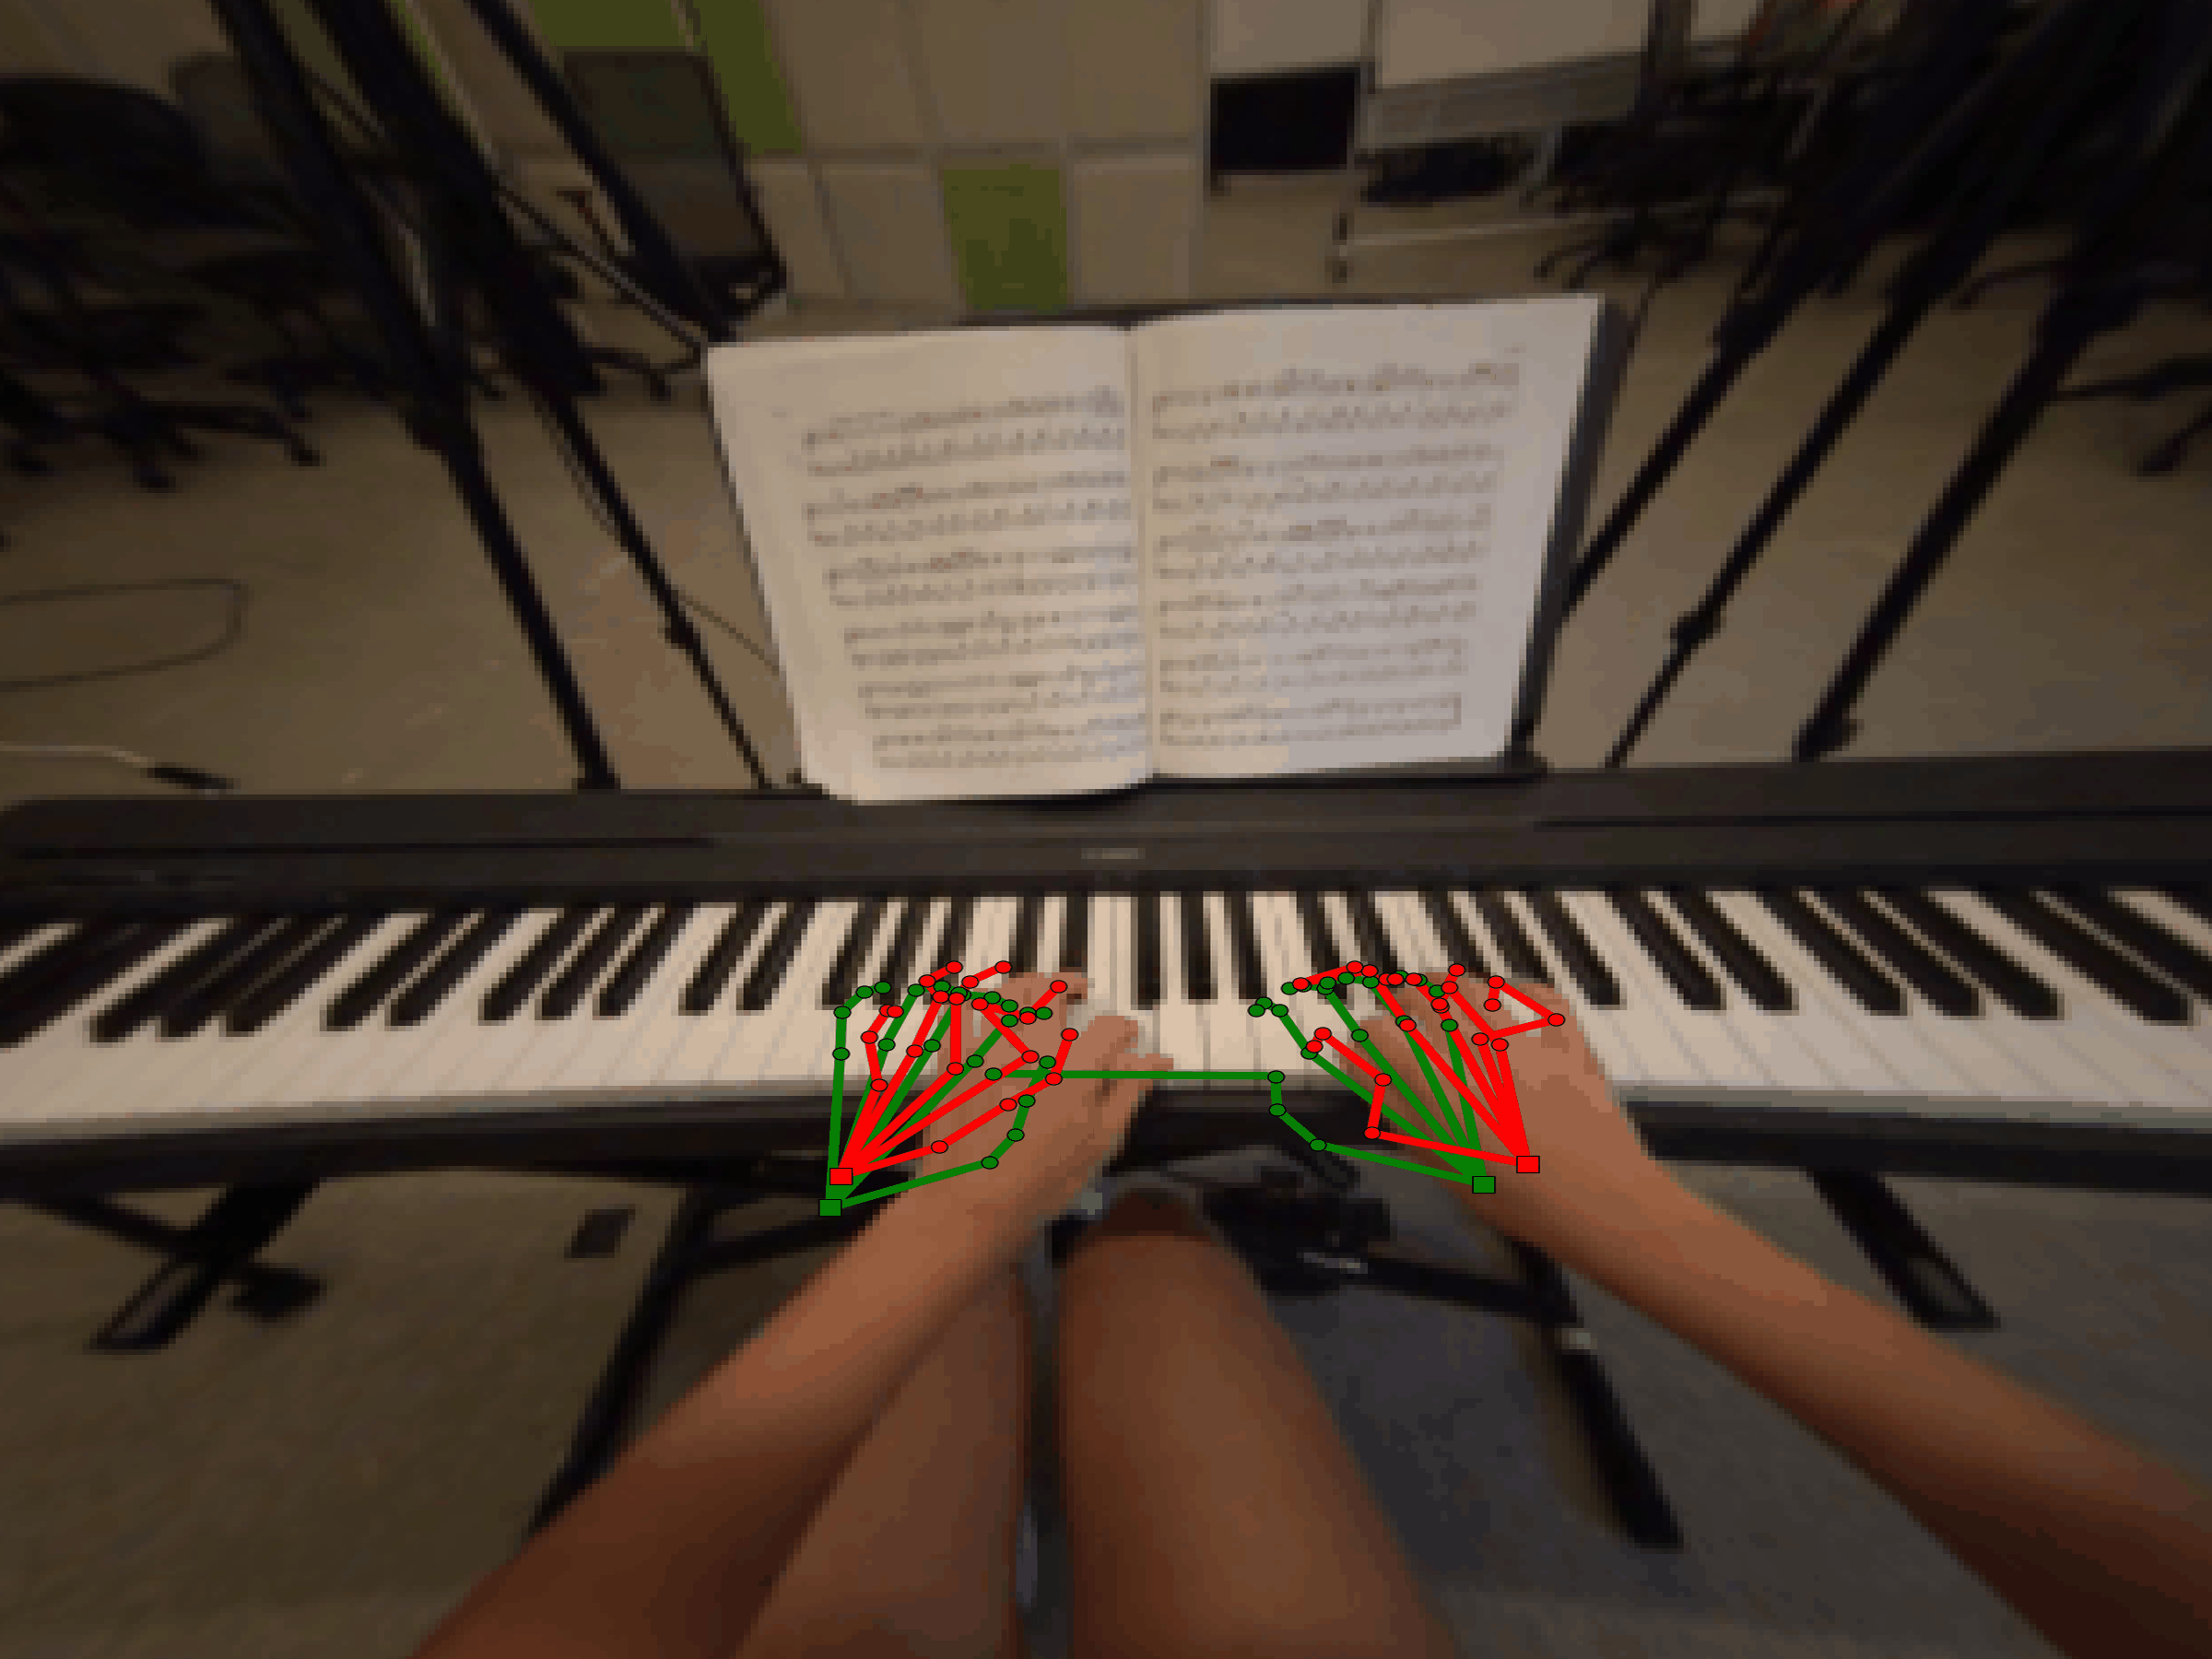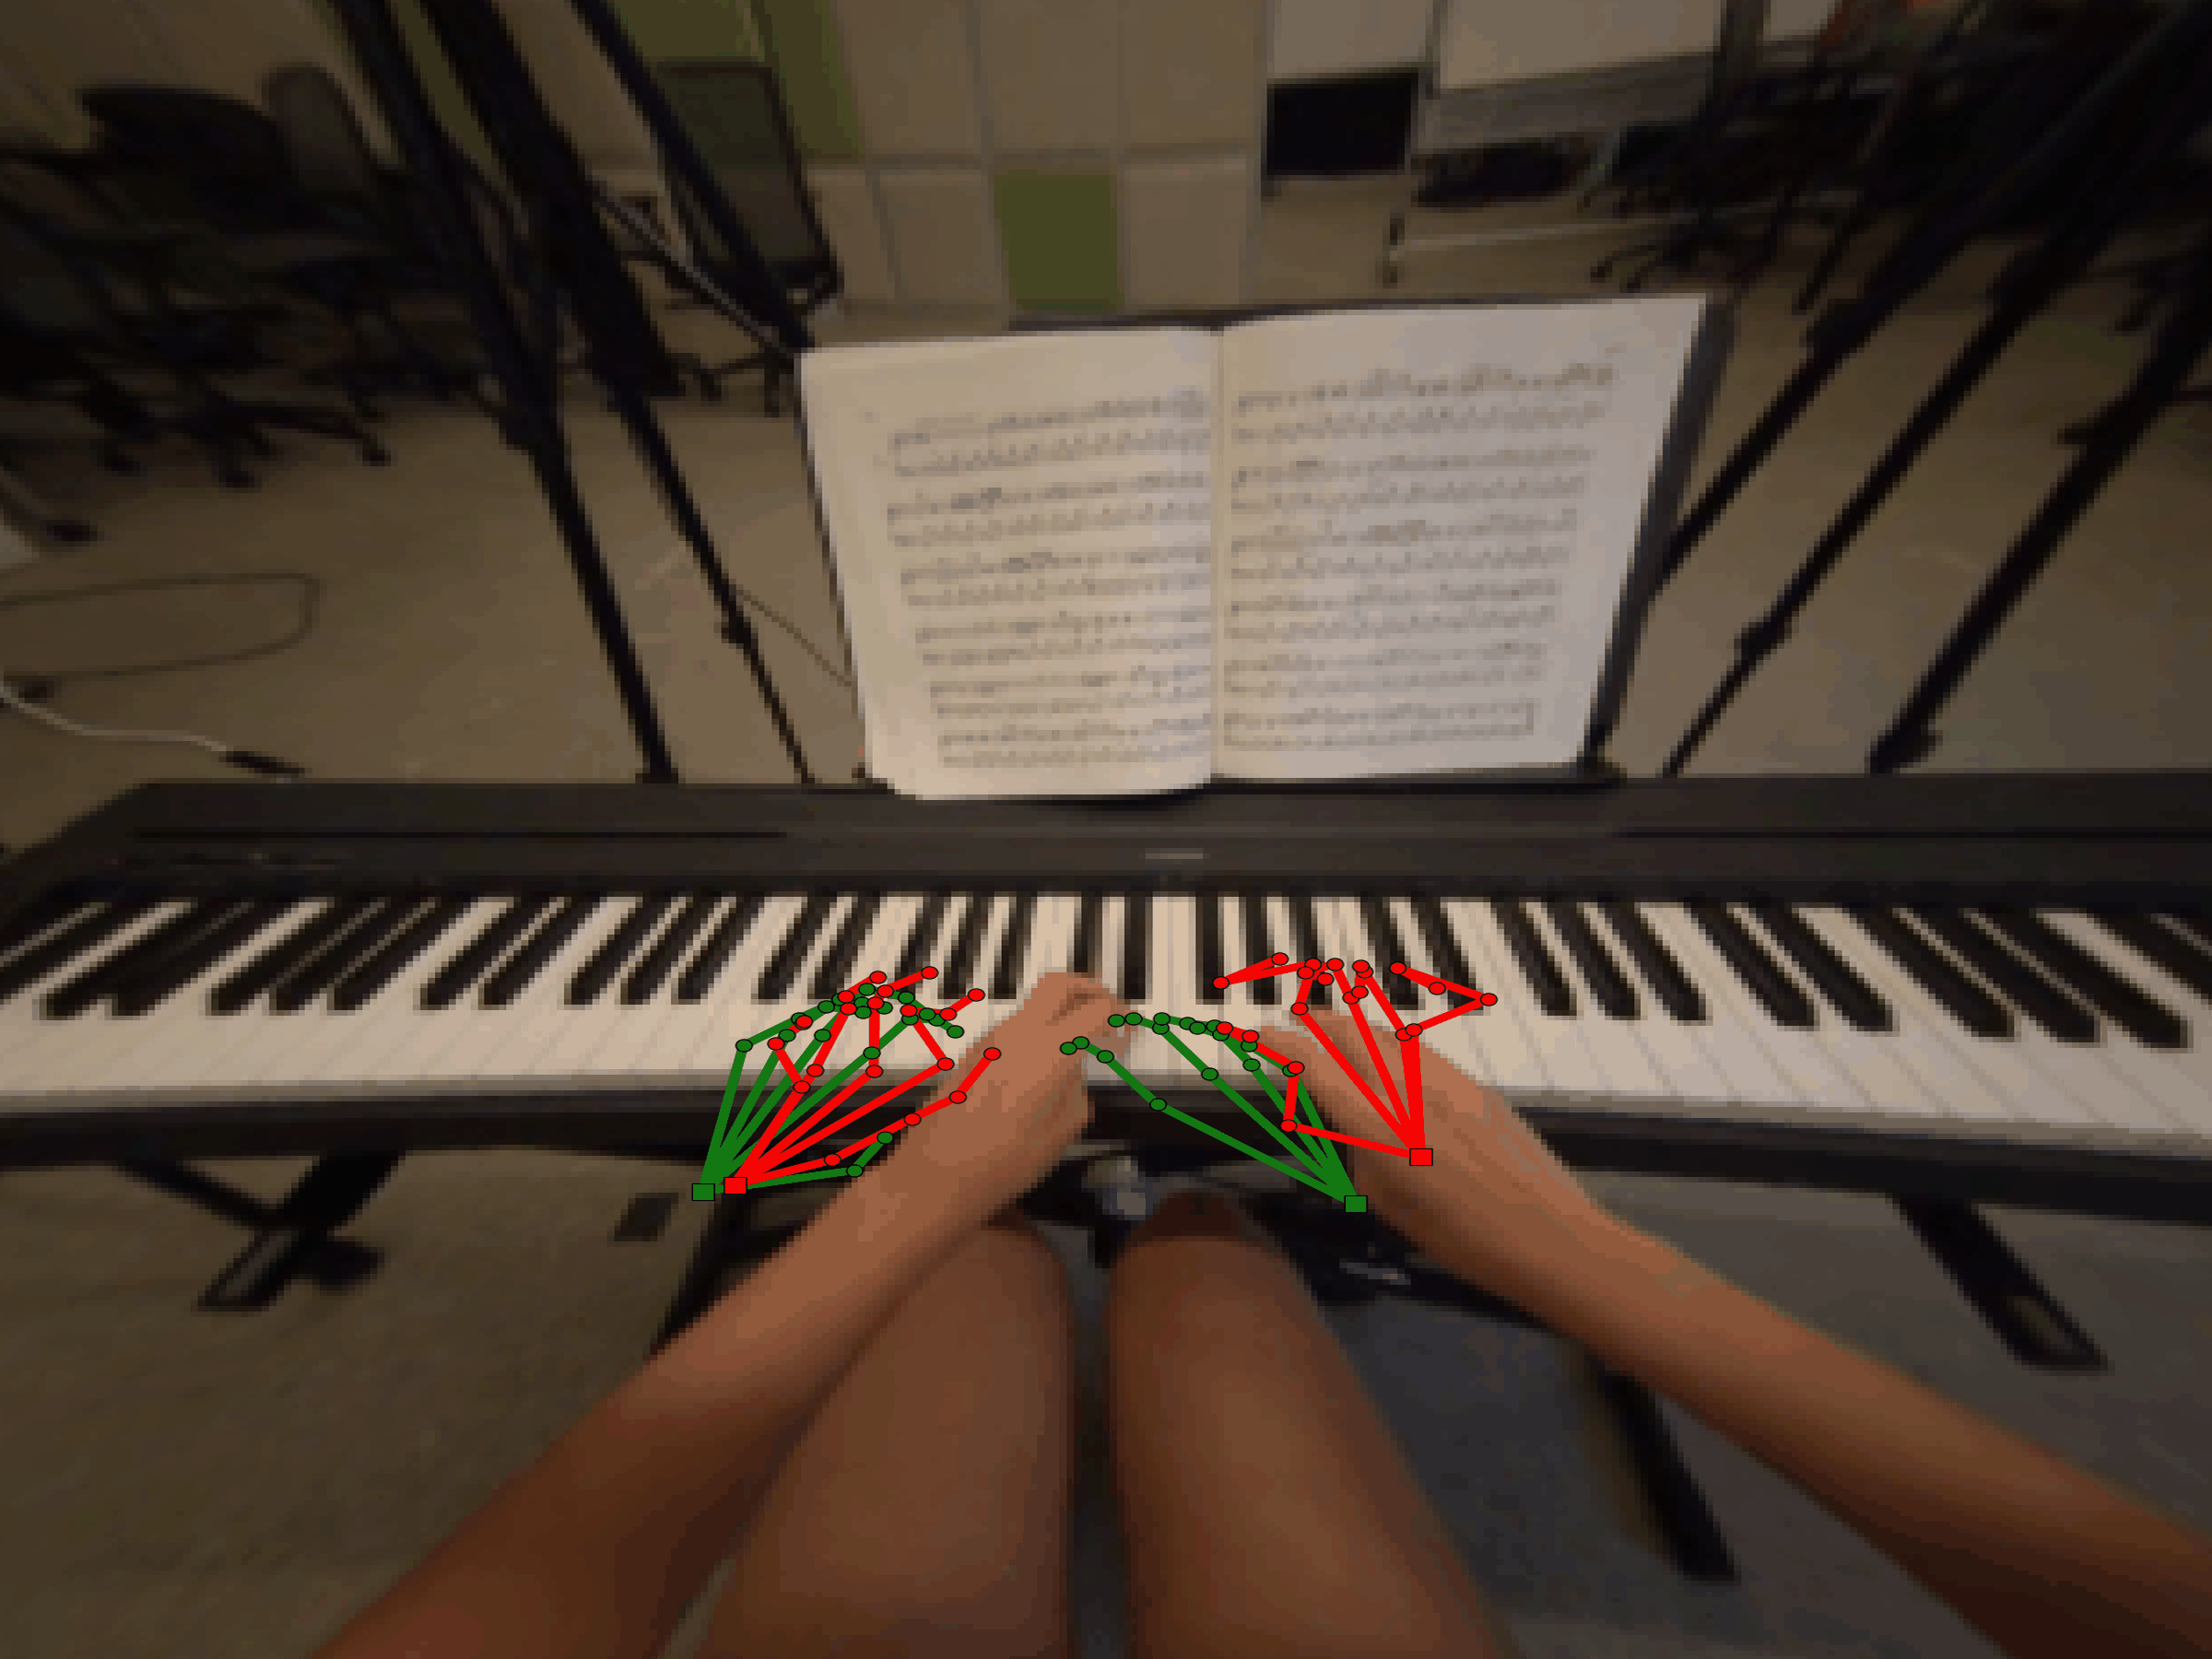
3D Hand Pose Sample
2D Hand Pose Sample
Human Motion Modeling
Research on modeling and generating human motion using generative AI techniques.
On-Device AI
Enabling reliable AI inference on resource-constrained devices by developing efficient model compression, adaptation, and deployment techniques for foundation models in real-world physical systems.
Computer Vision & Multimodal A.I.
Developing high-level scene understanding models such as semantic segmentation, object detection, and scene reconstruction for autonomous systems, robotics, and other applications.
Latest News
Two papers accepted at NeurIPS 2026
(1) “Learning Scene-Grounded Interaction Priors for Scene-Aware Human Motion Prediction” by Donghyeon Soon*, Jiil Yoon*, Hyeondong Kim and Daehee Park† (2) “SRA: Spatial Reasoning Adapter via Evolving Social Interaction Graphs for Trajectory Prediction” by Jaewoo Jeong*, Seonkyu Song*, Hyeonwoo Park, Jegyeong Cho, Yujin Bae, Giwon Lee, Daehee Park and Kuk-Jin Yoon† Congratulations to all authors 🎉
Taewon Seo received the Outstanding Student Award at the DGIST 22nd Anniversary Ceremony 🎖️
Taewon Seo received the Outstanding Student Award in recognition of his research achievements at the DGIST 22nd Anniversary Ceremony.
Awarded a 5-year research grant from the Ministry of Trade, Industry and Resources (MOTIR)
Project title: 숙련자 시연데이터 기반 조선소 작업 특화 양팔 모바일 매니퓰레이터 및 Physical AI 작업스킬 실증 플랫폼 개발
Two Master's Students Joined the ISL Lab 🎓️
Two new master’s students have joined the lab. Jiil Yoon joins from the Department of Electrical Engineering and Computer Science (EECS), and Myeonggeun Park from the Department of Artificial Intelligence (AI). Welcome to ISL Lab!

Awarded two GPU computing support grants (국가 AI데이터센터 고도화 사업, AI연구용 컴퓨팅 지원 프로젝트)
Project title: 도시형 생성 지능을 위한 사회적 군중 시뮬레이션 기술 개발 (H100 × 8) Project title: 희소 궤적 월드 액션 모델을 활용한 양손 조작 행동 생성 기술 개발 (H100 × 8)

One paper accepted at ECCV 2026
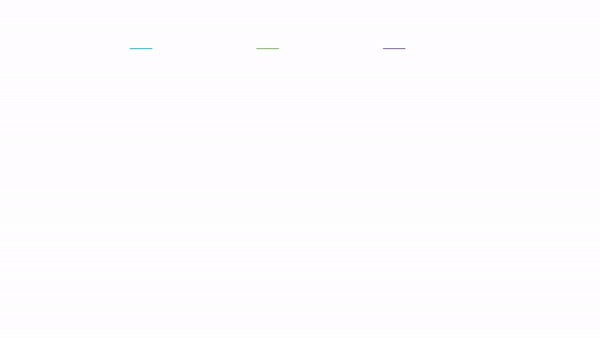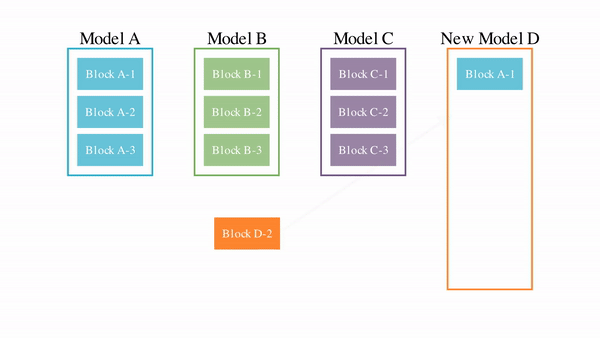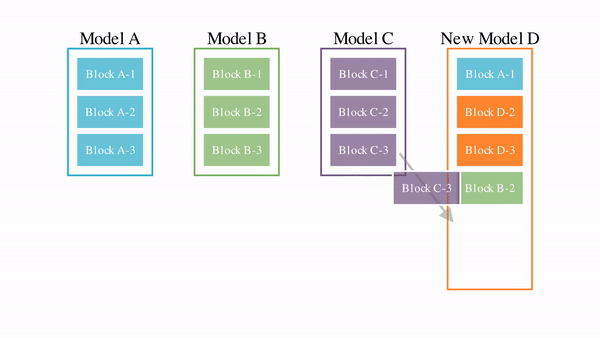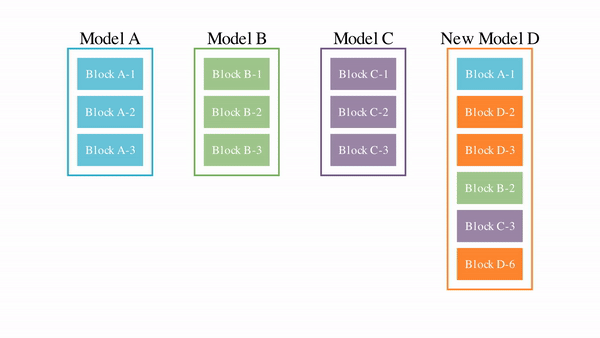
The paper is “Unified Prediction and Planning via Conflict-Aware Disjoint Parameter Training” by Taewon Seo*, Seonae Jeon*, Giwon Lee*, Kukjin Yoon† and Daehee Park†

Awarded three research grants for AI and robotics projects (미래유망융합기술파이오니어, K-콘텐츠 제작 기술개발, 첨단 GPU 활용 지원 사업)
Project title: 다중 휴머노이드의 자율 협업을 위한 비전-언어 모델 기반 적응형 장기·복합작업 계획 기술 Project title: 아카이브 영상 콘텐츠 활용을 위한 AI Outpainting 및 콘텐츠 변환 기술 개발 Project title: 한국형 Physical LLM 의 실시간성과 안정성을 위한 가변형 추론 프레임워크 개발
Awarded a 4-year research grant from the National Research Foundation of Korea (NRF 우수신진B)
Project title: 자기 진화형 Physical LLM: 불확실한 환경에서 행동 파운데이션 모델의 강건하고 효율적인 적응 기술 연구 News: Link

Two papers accepted at CVPR 2026 Findings
(1) “EggHand: A Multimodal Foundation Model for Egocentric Hand Pose Forecasting” by Jaeyoung Choi*, Hyeondong Kim*, Yujin Kim and Daehee Park (2) “BitTP: The Lightweight Trajectory Prediction Model with BitLLM for Edge-Devices” by Mincheol Kang*, Hyunjin Lim*, Bomin Kang* and Daehee Park Congratulations to all authors 🎉

One paper accepted at IEEE Signal Processing Letters
The paper is “CascadeOcc: Rethinking 3D Occupancy World Models with Cascaded VQ Representations ” by Kyumin Hwang*, Wonhyeok Choi*, Jaeyeul Kim, Jihun Park, Daehee Park† and Sunghoon Im†

Six Master's Students Joined the ISL Lab 🎓️
Six new master’s students have joined the lab. Hyungchul Shin joins from the Department of Electrical Engineering and Computer Science (EECS), and Youngjin Park, Hyunjin Lim, Sihyeong Lee, Hyeonwoo Park, Donggyu Lee from the Department of Artificial Intelligence (AI). Welcome to ISL Lab!

Awarded an NVIDIA Academic Hardware Grant
Project title: Extending Action Foundation Models to Dynamic Human-Robot Collaboration, for inclusion in our Academic Grant Program